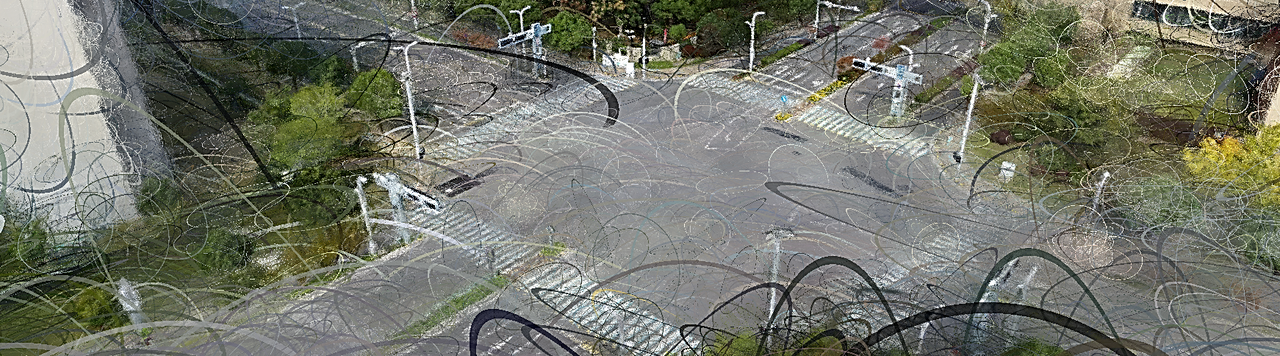
Reconstructed junction image from the original 11.6 cover

Publicly Owned Simulation Assets
for Autonomous Vehicle Admission

[1]

Yiyan Wang and Sijian Tian

Solidarity AI 2026 · Chulalongkorn University, Bangkok

Autonomous driving is entering public roads

Autonomous vehicle fleets worldwide

Estimated worldwide autonomous vehicle fleet sizes Fewer than roughly 4,000 in 2024, inferred from IEA data. About 8,000 robotaxis in 2025. About 10,000 autonomous vehicles in operation in September 2026, from a separate estimate. <4,000 ≈8,000 ≈10,000 2024 [2] 2025 [2] Sep 2026 [9]

2024–25 robotaxis (2024 inferred) · 2026 operating AVs (separate estimate)

36%

would feel unsafe riding in a self-driving carAverage across 31 countries [3]
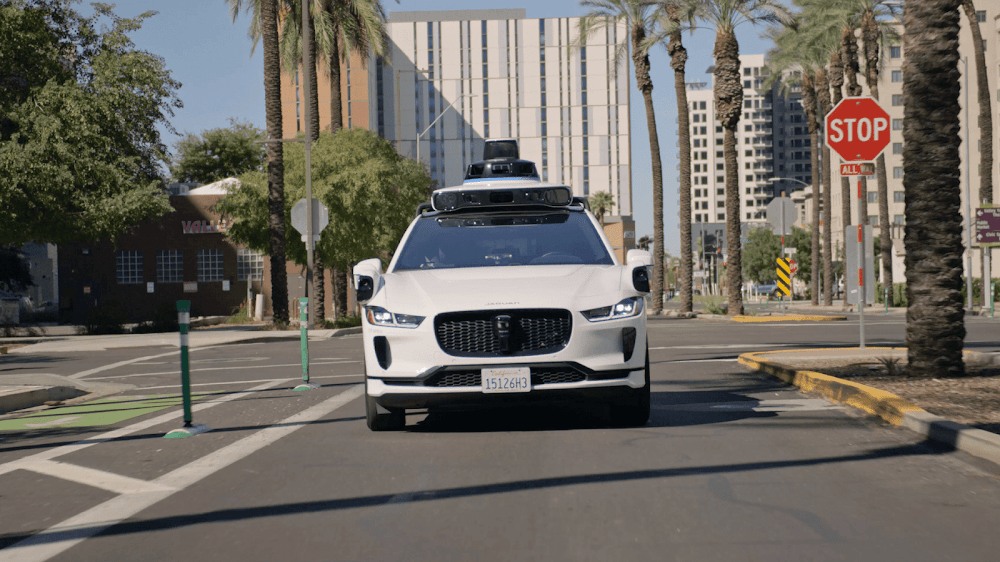
Waymo Jaguar I-PACE robotaxi on a city street
Waymo robotaxi Source: Waymo [5]
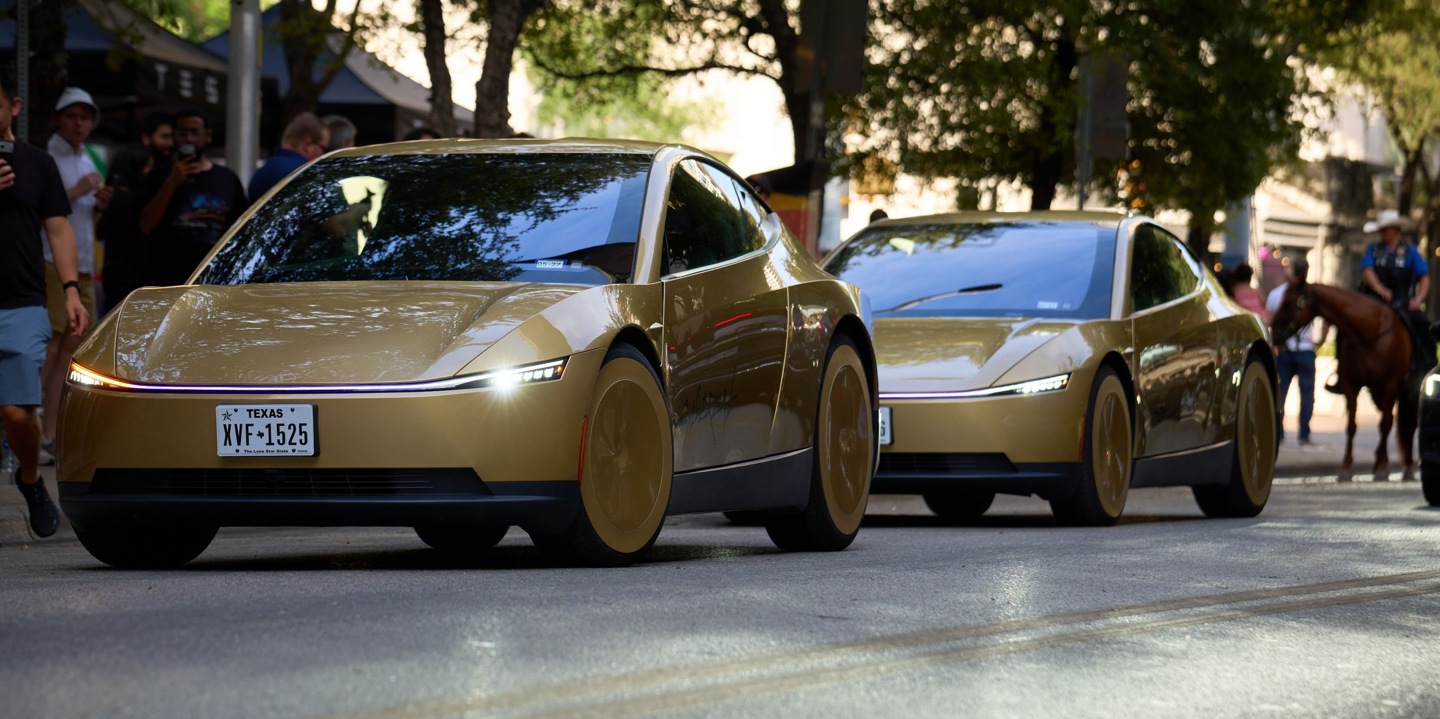
Gold Tesla Cybercabs on a street at their launch
Tesla Cybercab [4]

Access to testing and decisions is unequal

Developers and test teams

Test vehicles and driving systems

Authorities

Review the evidence

Road admission [6]

Who can operate on public roads

People who use the roads

Less access to evidence, testing tools and a say in decisions.

Could visualising traffic situations help narrow this gap?

Why start at a junction?

Vehicles, turns and crossings meet in one place.
40–60%

of road crashes occur at junctions in many countries. [7]
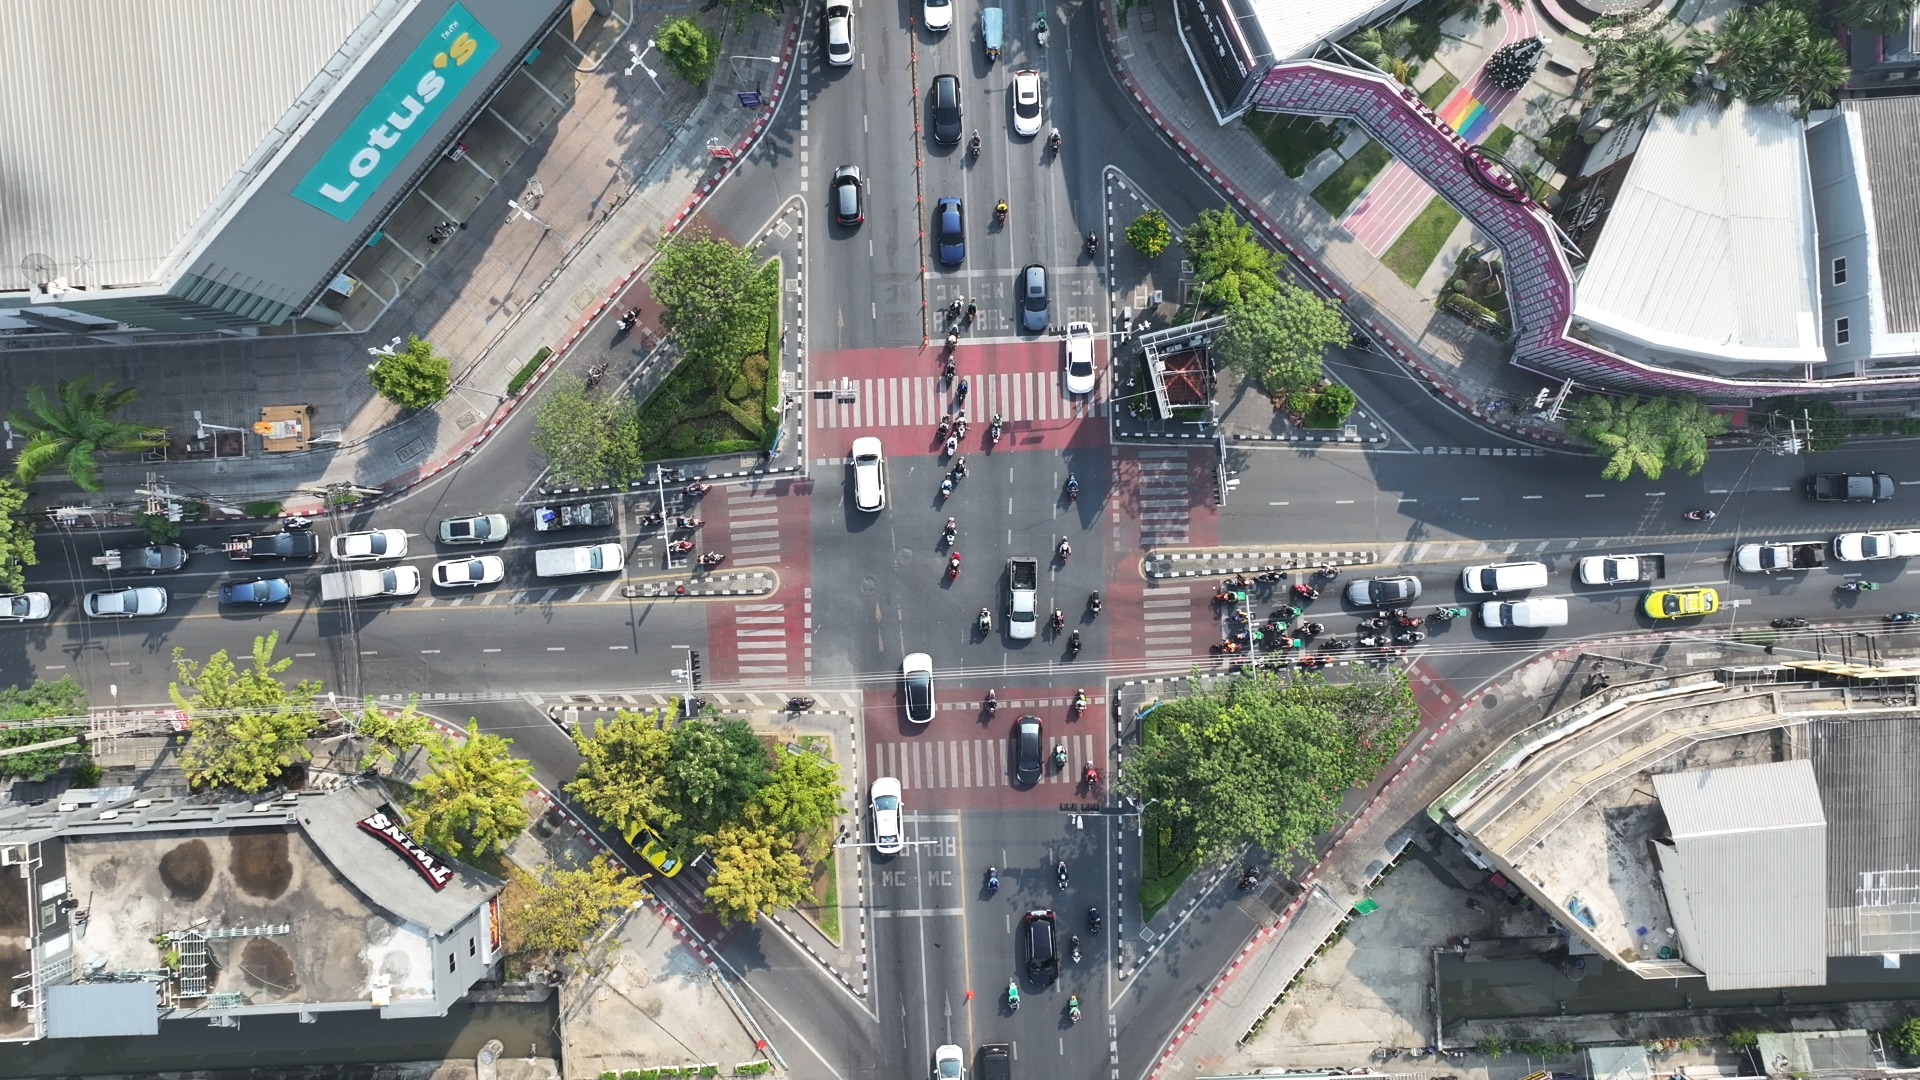
Aerial photo of a busy real junction
Traffic hub [8]
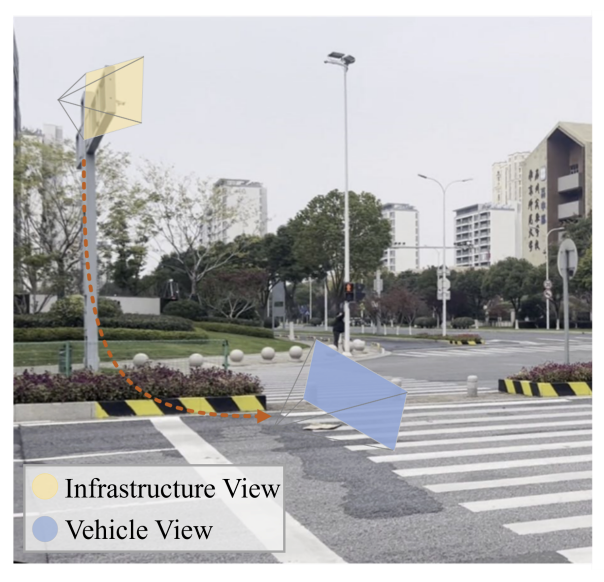
Original comparison of a fixed roadside camera and a moving vehicle viewpoint
Fixed roadside viewVehicle view [1]

Fixed cameras capture many interactions across the same junction over time.

Sparse, elevated and oblique views differ from what a vehicle sees.

I2V-FOCAL turns roadside views into reusable scenes

I2V-FOCAL: Fusion of Consistent Appearance and Lighting for Infrastructure-to-Vehicle Synthesis · Accepted at IROS 2026 [1]
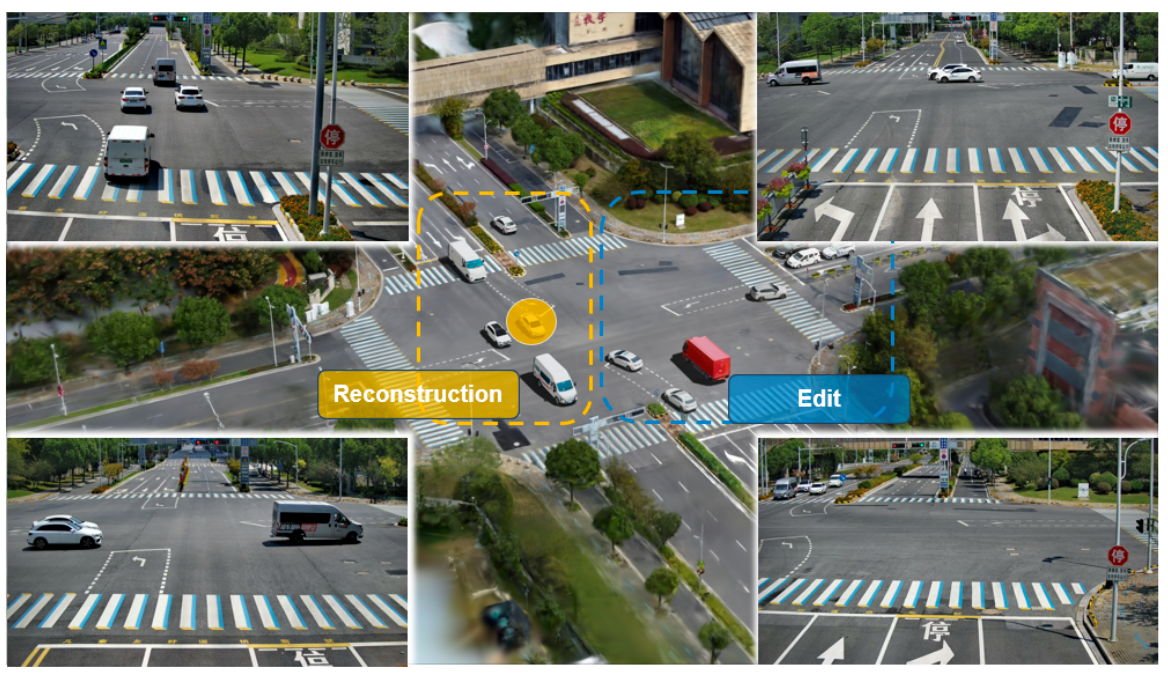
The original composite of four roadside views, the reconstructed junction and the editable scene [1]

Sparse roadside views

1Static background reconstruction

Reusable static 3DGS

2Dynamic vehicle reconstruction

Vehicle asset library

White van
Vehicle AState ta
Blue car
Vehicle BState tb
Purple truck
Vehicle CState tc
Red truck
Vehicle DState td

3Scenario composition

Sampling · Collision-aware placement · PBR relighting

(1) + (2) + (3)One captureReusable assetsMany ego-view scenarios

Example

Four roadside views as input

View 1 [1]
View 2 [1]
View 3 [1]
View 4 [1]

Example

Reconstruction outputs and editable scenarios
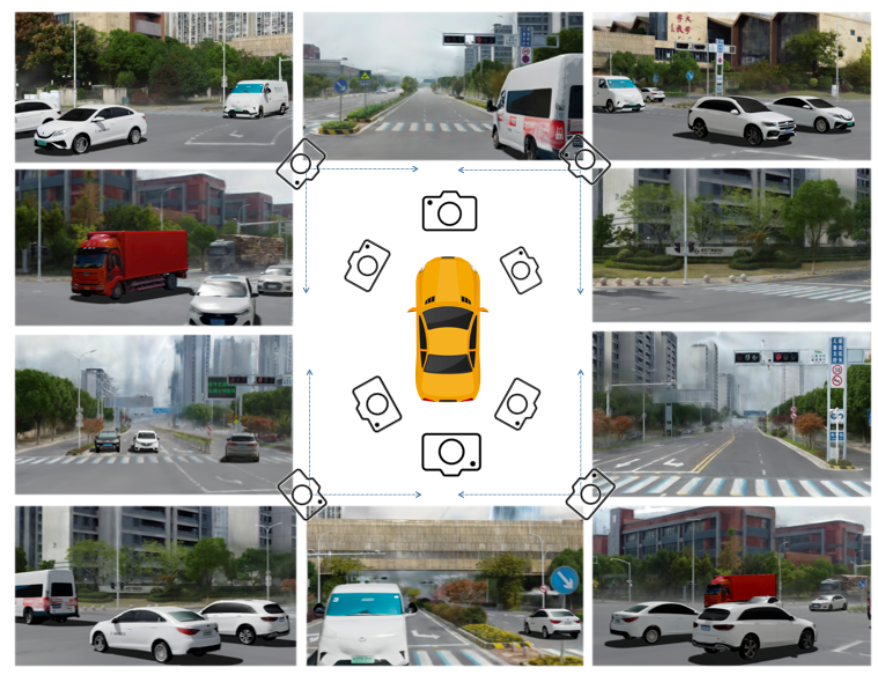
Original I2V-FOCAL figure showing several viewpoints around a vehicle
Views from around the vehicle [1]
Reconstructed junction [1]
Changed traffic [1]
Changed lighting [1]

PUBLIC OVERSIGHT

Proposed use

Public scrutiny before road admission

  1. 01

    A new release

    New vehicle
    or
    New driving algorithm
  2. 02

    Run it in the reconstructed junction

    Yield at an obscured crossing New system
  3. 03

    The public watches the same run

    Same test run
    Pass Fail

    Run 1 · In progress

PUBLIC EXPERIMENTATION

Proposed use

Different ways to explore the same junction

I2V vehicle and trajectory assets
Participant 1
Adds a minibus
Participant 2
Redraws a turn
Participant 3
Tries low sun

PUBLIC EXPERIMENTATION

Illustrative outcomes

Failed cases become feedback for evaluation

Passed this case Failed this case

A public role in autonomous-vehicle evaluation

Developers and test teams

Test vehicles and driving systems

Authorities

Review the evidence

Road admission [6]

Who can operate on public roads

People who use the roads

Can watch evaluations and bring failed cases back into testing.

A reusable visual environment gives road users a role in how vehicles are evaluated.

References

  1. [1]
    Wang, Y., et al. I2V-FOCAL: Fusion of Consistent Appearance and Lighting for Infrastructure-to-Vehicle Synthesis.IROS 2026. Original presentation materials (11.6.pptx).
  2. [2]
    International Energy Agency. Autonomous vehicles.2026. Global robotaxi fleet in 2025. The 2024 bound is inferred from the reported growth. iea.org
  3. [3]
    Ipsos. The Ipsos Mobility Report 2026.2026. Survey across 31 countries. ipsos.com
  4. [4]
    Tesla. Q3 2026 Update.2026. Cybercab launch photograph, p. 14. tesla.com
  5. [5]
    Waymo. Media Resources.Jaguar I-PACE in downtown Phoenix. Source: Waymo. waymo.com
  6. [6]
    Land Transport Authority, Singapore. Autonomous Vehicles.Overview of testing and road deployment. lta.gov.sg
  7. [7]
    European Road Safety Observatory. Junctions.Reported range for the share of crashes at junctions. road-safety.transport.ec.europa.eu
  8. [8]
    Roy, S. Charoen Phool Intersection.Roboflow Universe dataset. CC BY 4.0. universe.roboflow.com
  9. [9]
    Chambers, A. The Unseen Race to Power Autonomous Vehicle Fleets.Technology Magazine, 22 September 2026. Reports BloombergNEF’s worldwide operating-fleet estimate.